Computer science concepts
BFS, DFS, And Shortest Path Search
Demonstrate graph traversal skills: model grids/structures as graphs, pick the right search (unweighted vs weighted), and implement correct…
What's being tested
Demonstrate graph traversal skills: model grids/structures as graphs, pick the right search (unweighted vs weighted), and implement correct distance/reachability. Interviewers probe correct state representation, complexity reasoning, and edge-case handling like obstacles, multiple sources, and cycles.
Patterns & templates
-
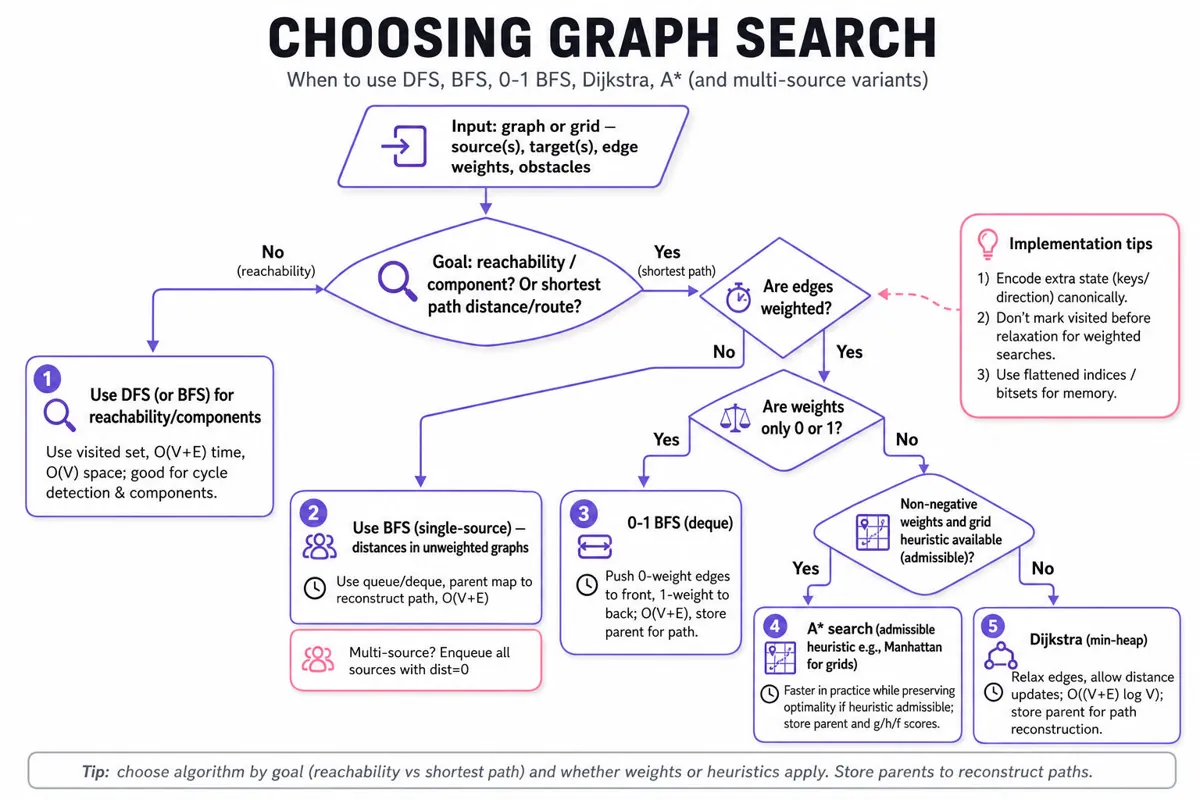
BFS on unweighted graphs/grids — use
deque,visited, andparentmap; distances inO(V+E)time andO(V)space. -
Multi-source BFS — enqueue all sources with distance 0 to compute nearest-source distances in one pass.
-
Dijkstra for non-negative weights — use
priority_queue(min-heap); complexityO((V+E) log V). -
0-1 BFS when weights are 0/1 — use
dequeto getO(V+E)time without a heap. -
A* heuristic search — admissible heuristic (e.g., Manhattan) to speed grid shortest-paths while preserving optimality.
-
State representation — encode position and extra state (keys, direction) as tuples/ints; canonicalize to avoid duplicates.
-
Path reconstruction — store
parent[node]during search; reconstruct by backtracking to avoid re-traversal costs.
Common pitfalls
Pitfall: Treating a grid cell as visited before considering better paths — in weighted graphs you must allow distance relaxation (use Dijkstra).
Pitfall: Forgetting diagonal vs orthogonal neighbor rules — clarify movement model and neighbor generation deltas.
Pitfall: Not bounding memory for large N — represent visited compactly (
bitset/flattened index) for big grids.